4. Test both stages#
The year 2017 was kept out of training and validation. Both stages run
on it as they would on a new survey: the detector with a low confidence
threshold (0.05), then the classifier on a chip around each detection,
dropping what it calls clutter. A detection is a hit when it overlaps
a labelled object by at least 10 % (intersection over union); the
objects are a few pixels across, so a stricter overlap punishes small
offsets more than real mistakes.
Result#
30 labelled objects in the test year:
Hits |
False alarms |
Misses |
Precision |
Recall |
|
|---|---|---|---|---|---|
Detector alone, threshold 0.25 |
4 |
5 |
26 |
0.44 |
0.13 |
Detector alone, threshold 0.05 |
20 |
57 |
10 |
0.26 |
0.67 |
Detector (0.05) + classifier |
15 |
26 |
15 |
0.37 |
0.50 |
The low threshold finds two thirds of the objects but raises 57 false alarms; the classifier removes more than half of them and loses five hits. With 30 test objects these numbers move a lot from run to run; the comparison between rows is the point, not the values.
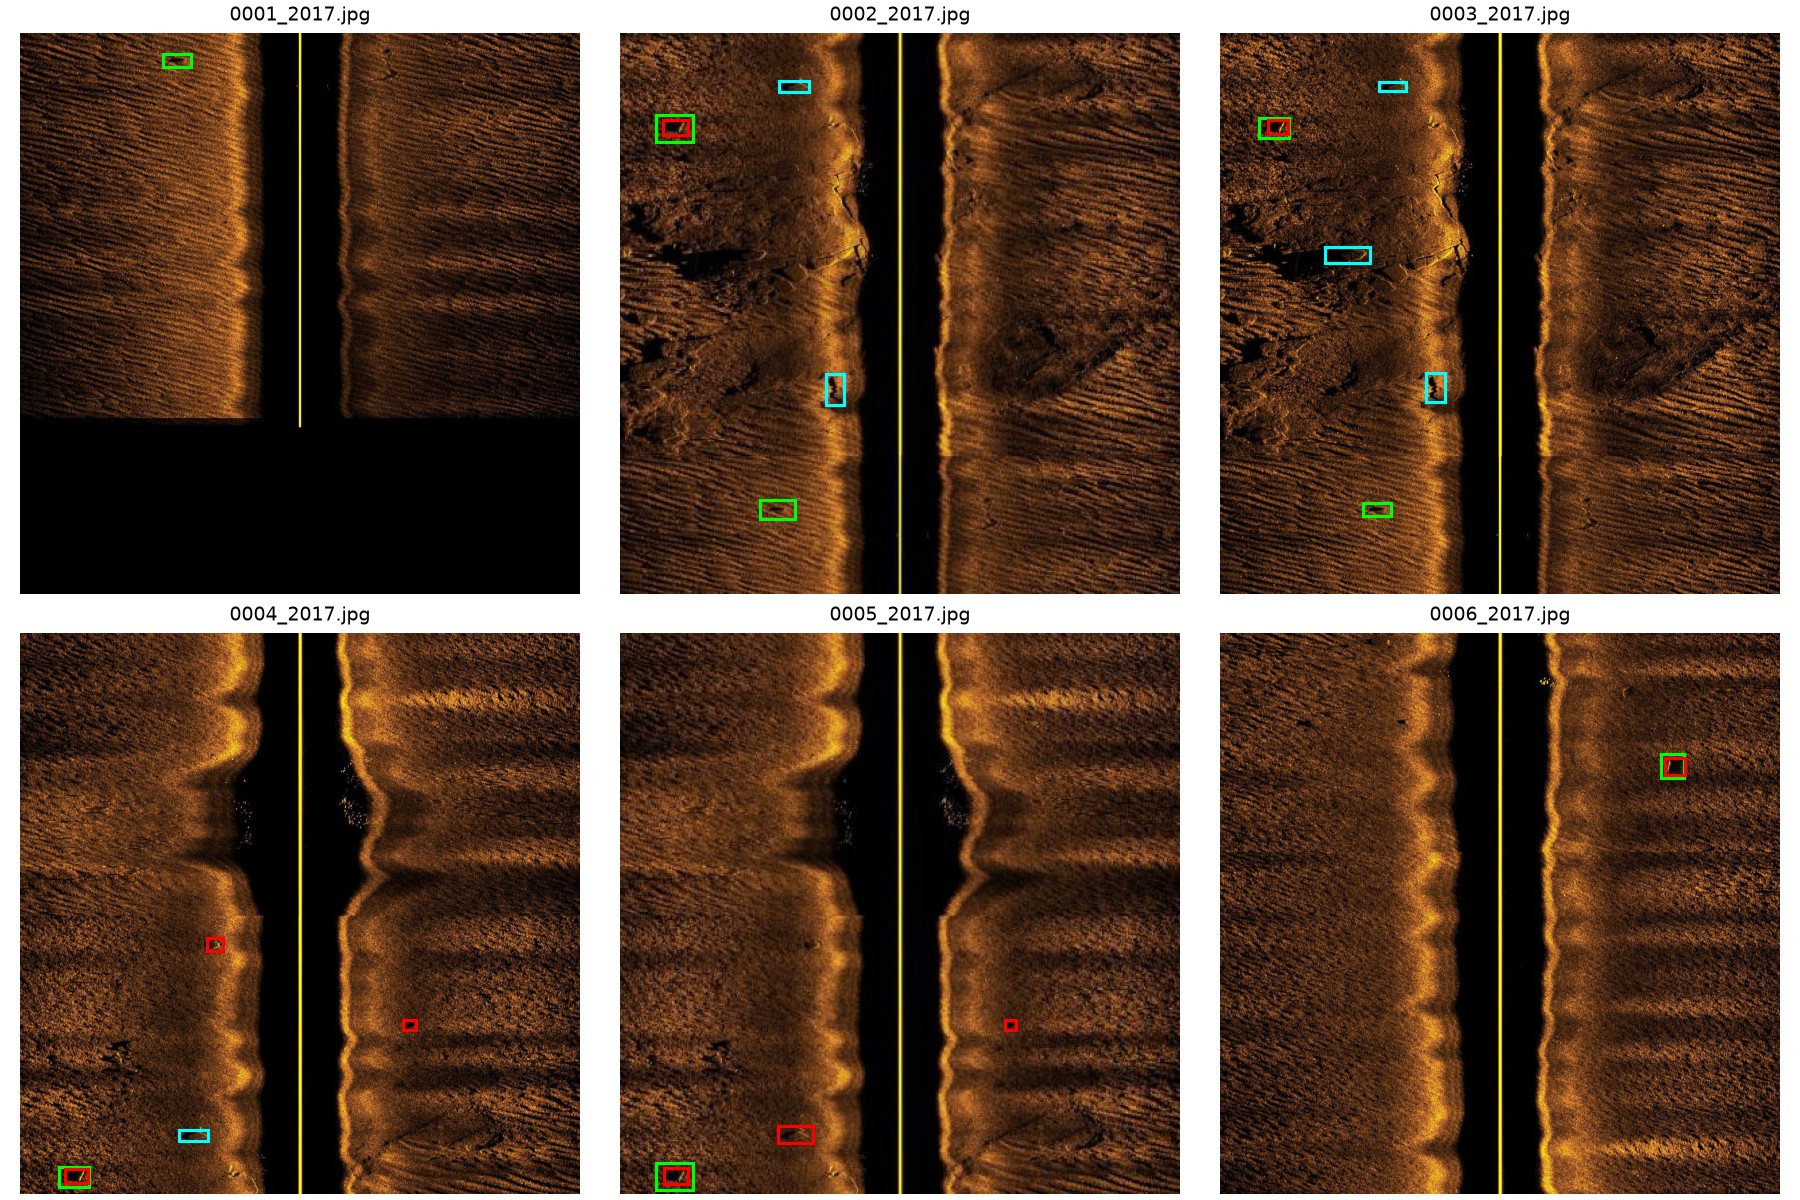
Labelled objects in green, two-stage calls in red (MILCO) and cyan
(NOMBO). On sonar data with positions the same comparison is made in
meters with targets.match_targets (step 6).
"""
Step 4: test both stages on the held-out year.

Compares the detector alone with detector plus classifier on 2017, matching boxes by
overlap (IoU >= 0.1), and draws a figure of test images.

Usage: python examples/atr/atr_4_evaluate.py ATR_DIR

See "Target recognition" in the sidescanpy docs for what each step does and its results.
"""

# 2026 rshomberg@uri.edu

import sys
from pathlib import Path

import matplotlib.pyplot as plt
import torch
from PIL import Image
from torch import nn
from torchvision import models, transforms
from ultralytics import YOLO

root = Path(sys.argv[1] if len(sys.argv) > 1 else "atr_santos")
CLASSES = ["MILCO", "NOMBO", "clutter"]
CHIP_PX, IOU_HIT = 64, 0.1
device = "cuda" if torch.cuda.is_available() else "cpu"

detector = YOLO(root / "runs" / "detector" / "weights" / "best.pt")
classifier = models.resnet18()
classifier.fc = nn.Linear(classifier.fc.in_features, len(CLASSES))
classifier.load_state_dict(torch.load(root / "classifier.pt", map_location=device))
classifier = classifier.to(device).eval()
to_tensor = transforms.Compose([transforms.ToTensor(),
                                transforms.Normalize([0.485, 0.456, 0.406], [0.229, 0.224, 0.225])])


def read_boxes(txt):
    t = txt.read_text().split()
    return [(int(t[i]), *map(float, t[i + 1:i + 5])) for i in range(0, len(t), 5)]


def chip(image, xc, yc, w, h):
    W, H = image.size
    side = max(32.0, 3 * max(w * W, h * H))
    x0, y0 = xc * W - side / 2, yc * H - side / 2
    return image.crop((round(x0), round(y0), round(x0 + side), round(y0 + side))).resize((CHIP_PX, CHIP_PX))


def iou(a, b):
    """Boxes as (xc, yc, w, h), relative units."""
    ax0, ay0, ax1, ay1 = a[0] - a[2] / 2, a[1] - a[3] / 2, a[0] + a[2] / 2, a[1] + a[3] / 2
    bx0, by0, bx1, by1 = b[0] - b[2] / 2, b[1] - b[3] / 2, b[0] + b[2] / 2, b[1] + b[3] / 2
    inter = max(0, min(ax1, bx1) - max(ax0, bx0)) * max(0, min(ay1, by1) - max(ay0, by0))
    return inter / (a[2] * a[3] + b[2] * b[3] - inter)


def score(dets, truth):
    """Greedy one-to-one matching per image; returns hits, false alarms, misses."""
    hits = fa = misses = 0
    for name, boxes in truth.items():
        d = sorted(dets.get(name, []), key=lambda r: -r[1])
        used = set()
        for box, _, _ in d:
            j = max(range(len(boxes)), key=lambda k: iou(box, boxes[k][1:]), default=None)
            if j is not None and j not in used and iou(box, boxes[j][1:]) >= IOU_HIT:
                used.add(j)
                hits += 1
            else:
                fa += 1
        misses += len(boxes) - len(used)
    return hits, fa, misses


# %%
# Run both stages on every test image.

images = sorted((root / "images" / "2017").glob("*.jpg"))
truth = {p.name: read_boxes(p.with_suffix(".txt")) for p in images}
alone, alone_low, two_stage = {}, {}, {}
for path in images:
    image = Image.open(path).convert("RGB")
    result = detector.predict(path, conf=0.05, imgsz=640, verbose=False)[0]
    boxes = result.boxes.xywhn.cpu().numpy()
    confs = result.boxes.conf.cpu().numpy()
    alone_low[path.name] = [(tuple(b), float(c), "object") for b, c in zip(boxes, confs)]
    alone[path.name] = [d for d in alone_low[path.name] if d[1] >= 0.25]
    if len(boxes):
        x = torch.stack([to_tensor(chip(image, *b)) for b in boxes]).to(device)
        with torch.no_grad():
            labels = classifier(x).argmax(1).cpu().numpy()
        two_stage[path.name] = [(tuple(b), float(c), CLASSES[k])
                                for b, c, k in zip(boxes, confs, labels) if CLASSES[k] != "clutter"]

# %%
# Results.

for name, dets in [("detector alone, conf 0.25", alone), ("detector alone, conf 0.05", alone_low),
                   ("detector (conf 0.05) + classifier", two_stage)]:
    h, fa, m = score(dets, truth)
    print(f"{name:34s} {h:3d} hits, {fa:3d} false alarms, {m:3d} misses: "
          f"precision {h / max(h + fa, 1):.2f}, recall {h / max(h + m, 1):.2f}")

milco = {n: [b for b in bs if b[0] == 0] for n, bs in truth.items()}
called = {n: [d for d in ds if d[2] == "MILCO"] for n, ds in two_stage.items()}
h, fa, m = score(called, milco)
print(f"{'two-stage, MILCO only':34s} {h:3d} hits, {fa:3d} false alarms, {m:3d} misses")

# %%
# Some test images with their labels (green) and the two-stage output
# (red: MILCO, cyan: NOMBO).

shown = [p for p in images if truth[p.name]][:6]
fig, axes = plt.subplots(2, 3, figsize=(12, 8), constrained_layout=True)
for ax, path in zip(axes.ravel(), shown):
    image = Image.open(path)
    W, H = image.size
    ax.imshow(image)
    for _, xc, yc, w, h in truth[path.name]:
        ax.add_patch(plt.Rectangle(((xc - w / 2) * W - 4, (yc - h / 2) * H - 4), w * W + 8, h * H + 8,
                                   fill=False, edgecolor="lime", linewidth=1.5))
    for (xc, yc, w, h), _, label in two_stage.get(path.name, []):
        ax.add_patch(plt.Rectangle(((xc - w / 2) * W, (yc - h / 2) * H), w * W, h * H, fill=False,
                                   edgecolor="red" if label == "MILCO" else "cyan", linewidth=1.5))
    ax.set_title(path.name, fontsize=9)
    ax.set_axis_off()
(root / "figures").mkdir(exist_ok=True)
fig.savefig(root / "figures" / "atr_test.png", dpi=150)